Blog
Huawei Cloud Embodied AI Competition 2026: Teleoperation and Data Collection with Star Arm 102

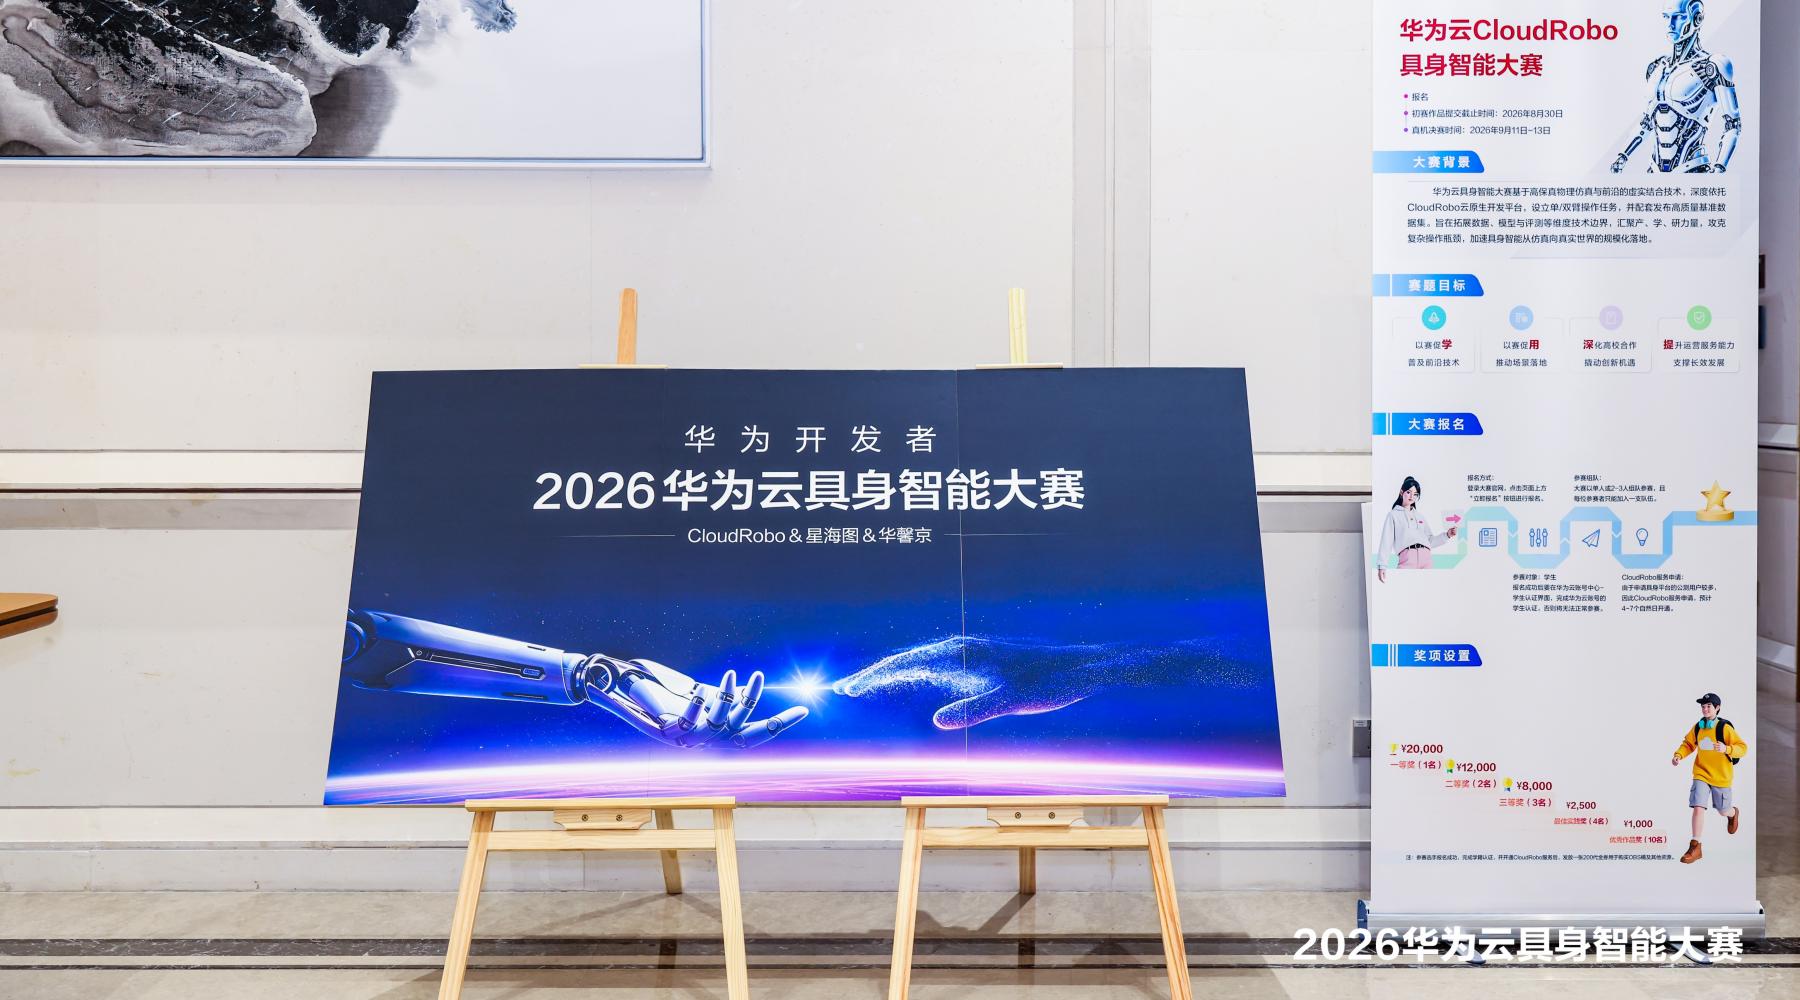
Star Arm 102 served as the teleoperation and data-collection platform at the 2026 Huawei Cloud Embodied AI Competition finals, supporting ten university teams as they captured demonstration data on real robotic hardware and deployed learned policies onto a live task.
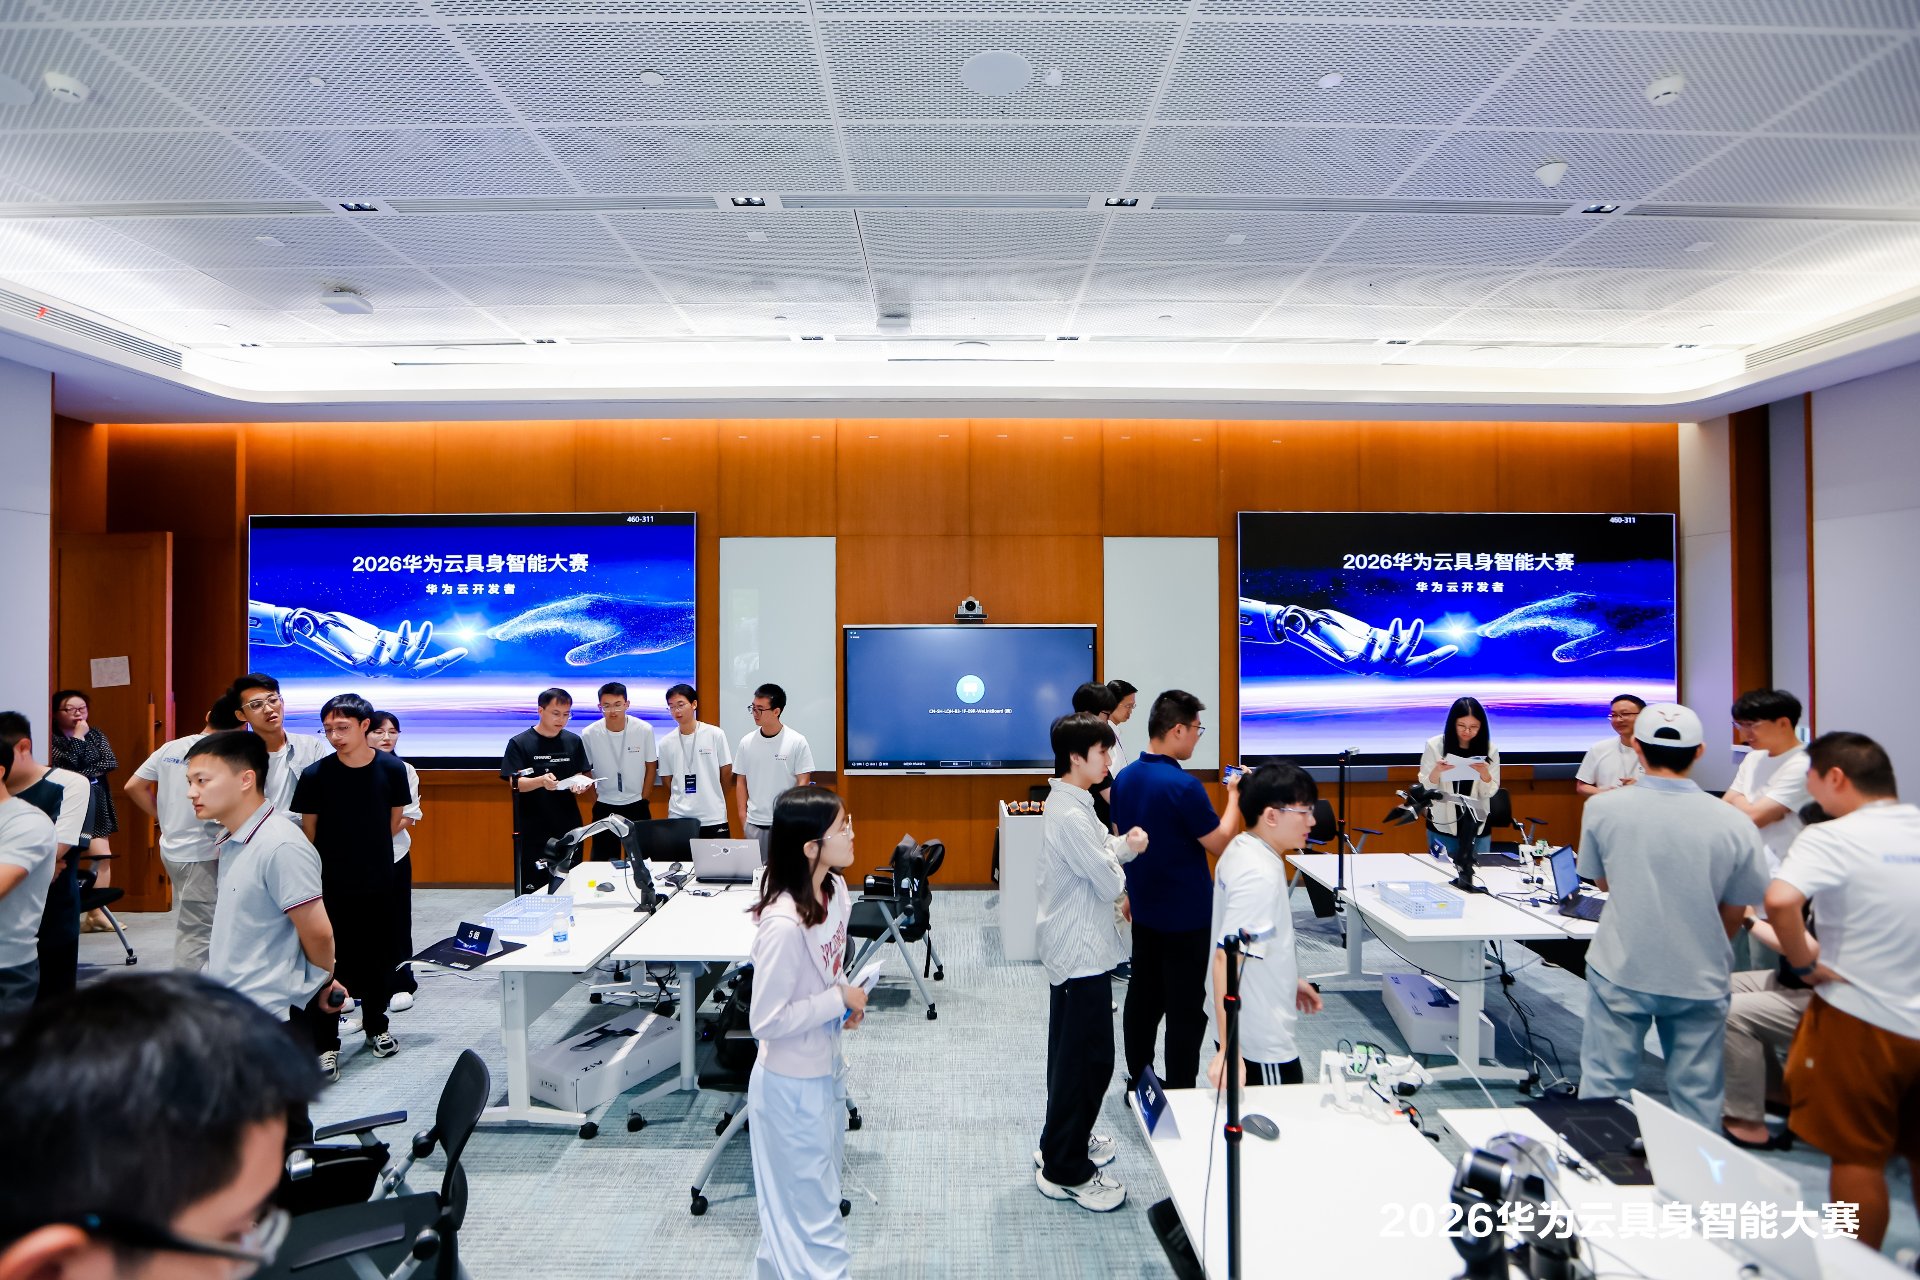
Held from September 11–13, 2026 at Huawei’s Lianqiuhu R&D Center in Shanghai, the Huawei Cloud Embodied AI Competition drew 147 registered teams and 422 participants from universities across China. Ten teams advanced from the simulation stage to compete in the on-site finals, where Fashion Star participated as an ecosystem adaptation partner of Galaxea, supplying the teleoperation and data-collection equipment used on the competition floor.
Event Application: At the Huawei Cloud Embodied AI Competition, Star Arm 102 was provided as the human-operated leader arm for teleoperation and demonstration data collection, supporting a direct path from human demonstration to robot-learning data.
The Huawei Cloud Embodied AI Competition: From Simulation to Real Hardware
Announced on June 5, 2026 at the INSPIRE 2026 Huawei Cloud Innovators Summit, the Huawei Cloud Embodied AI Competition is a first-of-its-kind event open to full-time university students, competing individually or in teams of two to three. It is split into two stages: an online simulation round and an on-site real-hardware final.
The simulation round closed on August 30, 2026. Teams developed and tested robot manipulation policies in a simulated environment, covering data collection and synthesis, simulation training, model training, model deployment and model evaluation. Ten teams advanced.
For the finals, the environment shifted from simulation to physical robots. Teams deployed the policies they had trained in simulation onto real hardware and completed a tabletop object-organization task across three days — running data collection, model deployment, robot control and task validation end to end. The Huawei Cloud Embodied AI Competition was organized around CloudRobo, Huawei Cloud’s Embodied AI Development Platform, which covers the full development chain from asset management and data processing to model deployment, evaluation and real-robot testing.
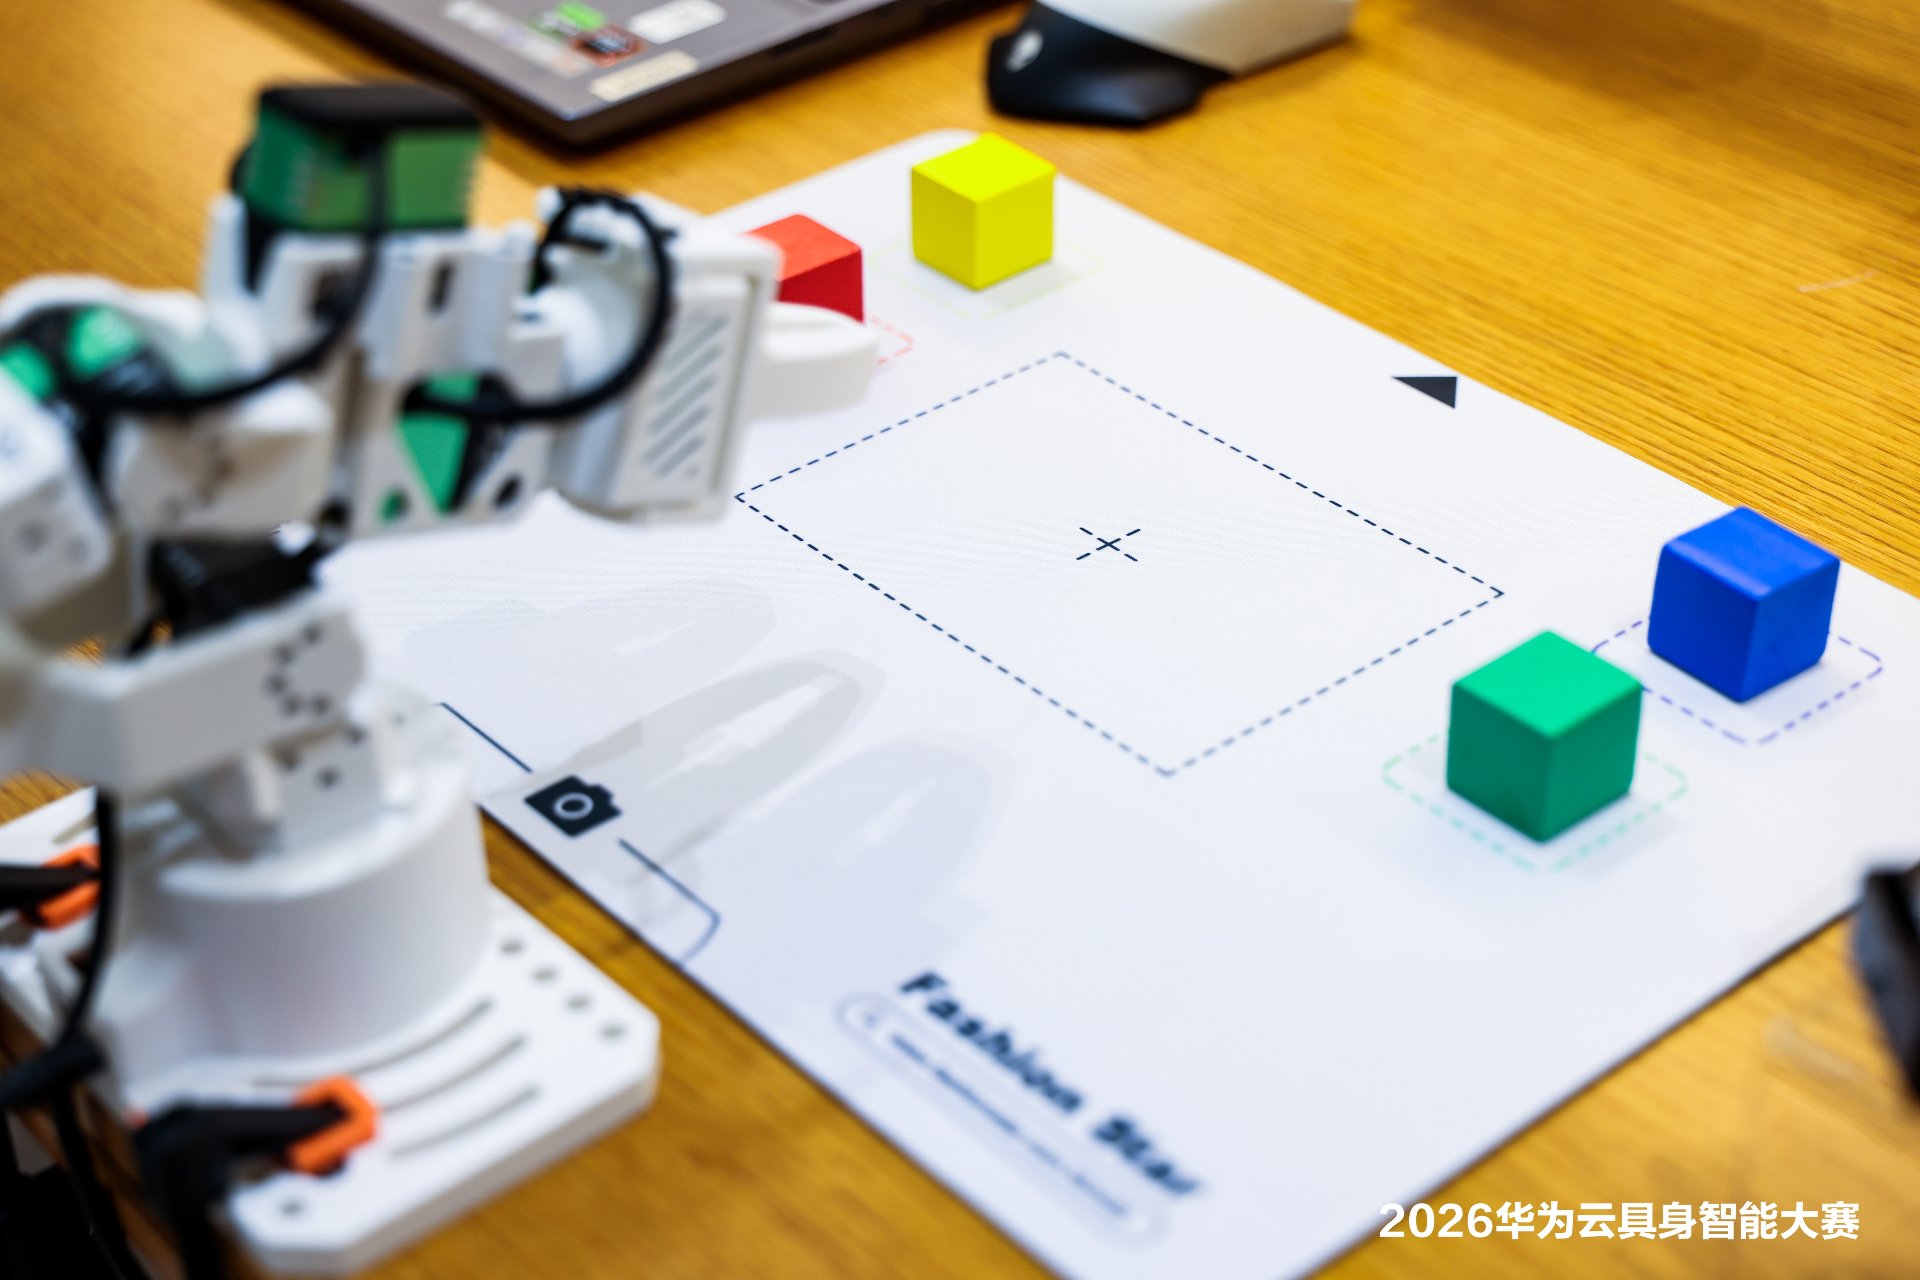
This simulation-first, hardware-second structure reflects how embodied AI is actually being deployed today: a policy has to work not only in training, but in the physical world.
Why Demonstration Data Decides the Outcome
In a Sim2Real workflow, the ceiling is usually set by data rather than by the algorithm. A policy trained in simulation still needs real demonstration data for fine-tuning and validation, and the quality of that data determines how well the policy performs once it reaches physical hardware.
That places specific demands on the arm used to capture demonstrations. It has to be light enough for hours of continuous handheld teaching. It has to hold its pose when released, so operators are not re-aligning the arm before every recording. It has to produce repeatable joint readings across repeated passes of the same trajectory. And it has to be quick to set up, because competition teams have three days, not three weeks.
Star Arm 102 as the Leader Arm
At the Huawei Cloud Embodied AI Competition, Star Arm 102 acted as the human-operated leader arm. Rather than programming every movement by hand, an operator could move the leader arm while the follower side reproduced the corresponding motion, with joint states and camera observations recorded as training data.
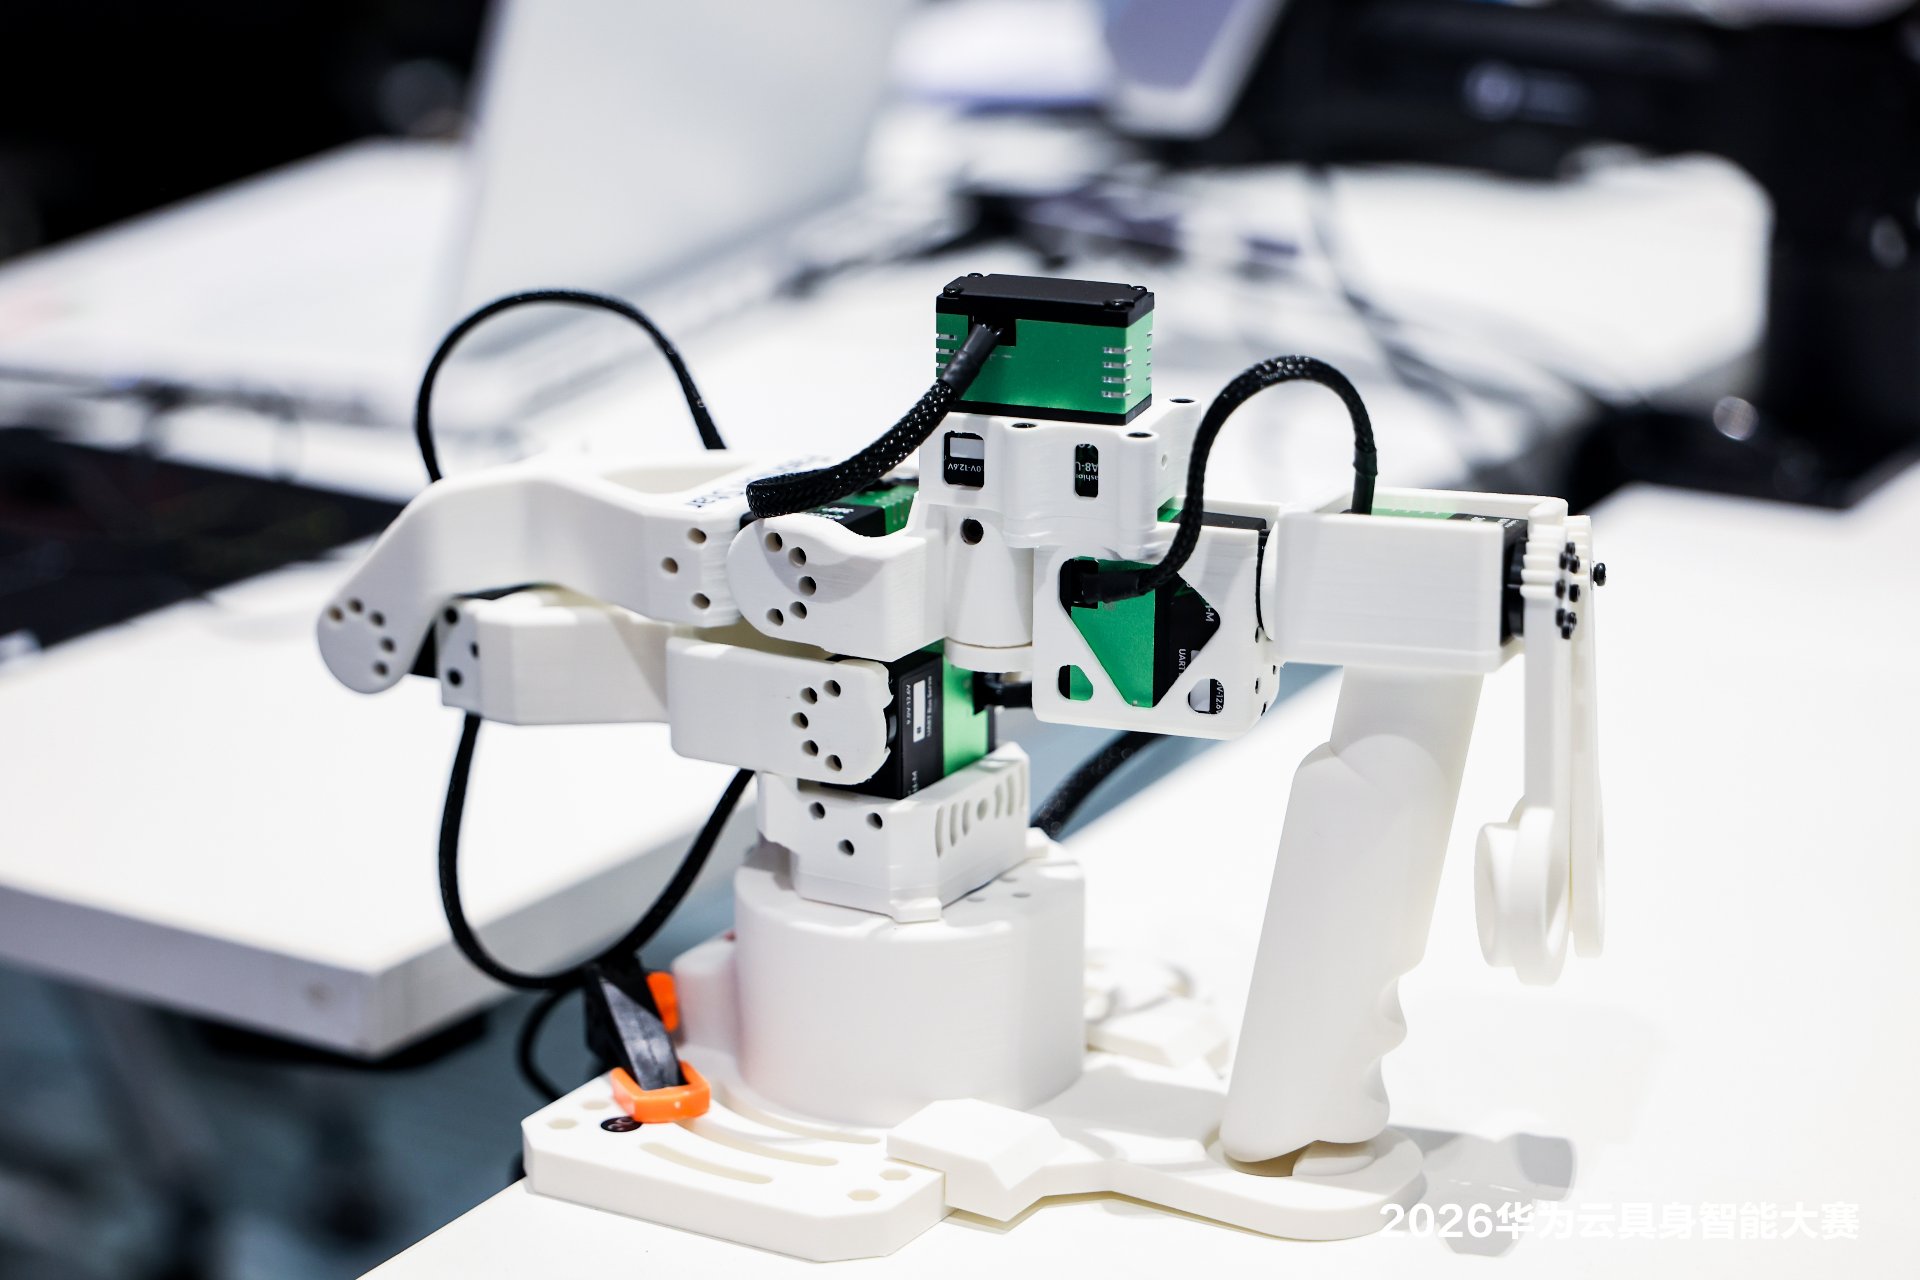
On the execution side, teams worked with the Galaxea A1Z robotic arm platform supplied as the competition’s hardware base. The Star Arm ecosystem supports flexible leader–follower pairings across compatible models — including Star Arm 102-FL, reBot Arm B601, Galaxea A1Z, PiPER-X and YAM Arm — so a single leader arm interface can be used with different follower hardware.
Three Stages Supported by the Workflow
The workflow Star Arm 102 supported at the Huawei Cloud Embodied AI Competition runs in three stages, each feeding the next.
1. Teleoperation
Directly control the follower arm to test task setups and refine the operating process before recording.
2. Data Collection
Record joint states, actions, and synchronized camera observations as structured demonstration data.
3. Imitation Learning
Use the captured demonstrations as training data for learned robot policies, then deploy the trained model back onto physical hardware.
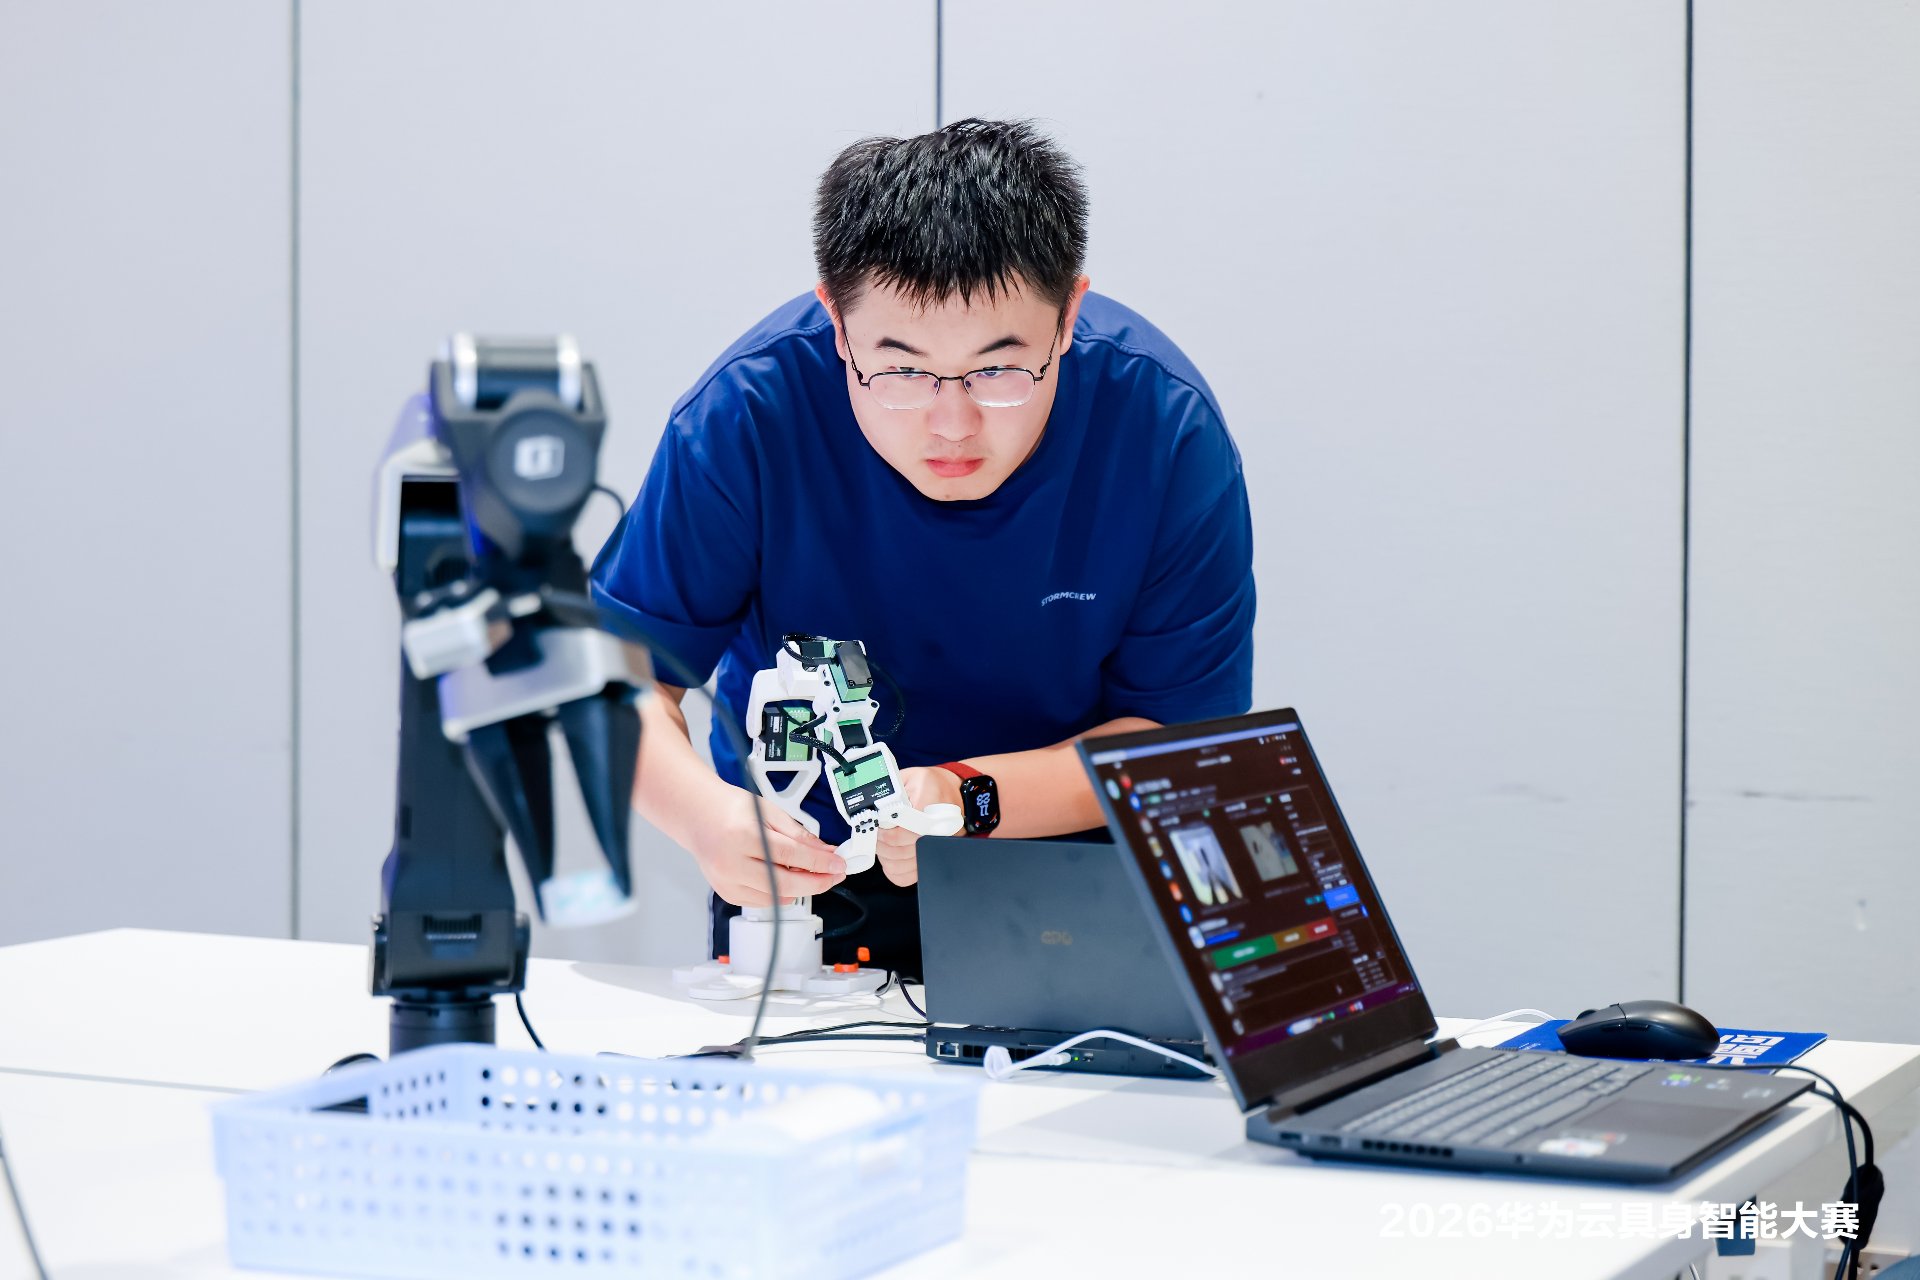
For a three-day final, this approach let teams begin from a working human-controlled process. They could validate a task through teleoperation, collect representative demonstrations, and use the resulting data as the foundation for robot-learning experiments — without losing time to hardware setup.
The Star Arm 102 Series
Star Arm 102 is an open-source 6+1 DoF robotic arm platform for teleoperation, data collection and embodied AI development. It is the leader arm that Fashion Star supplied for the Huawei Cloud Embodied AI Competition. The series covers leader and follower roles across three models:
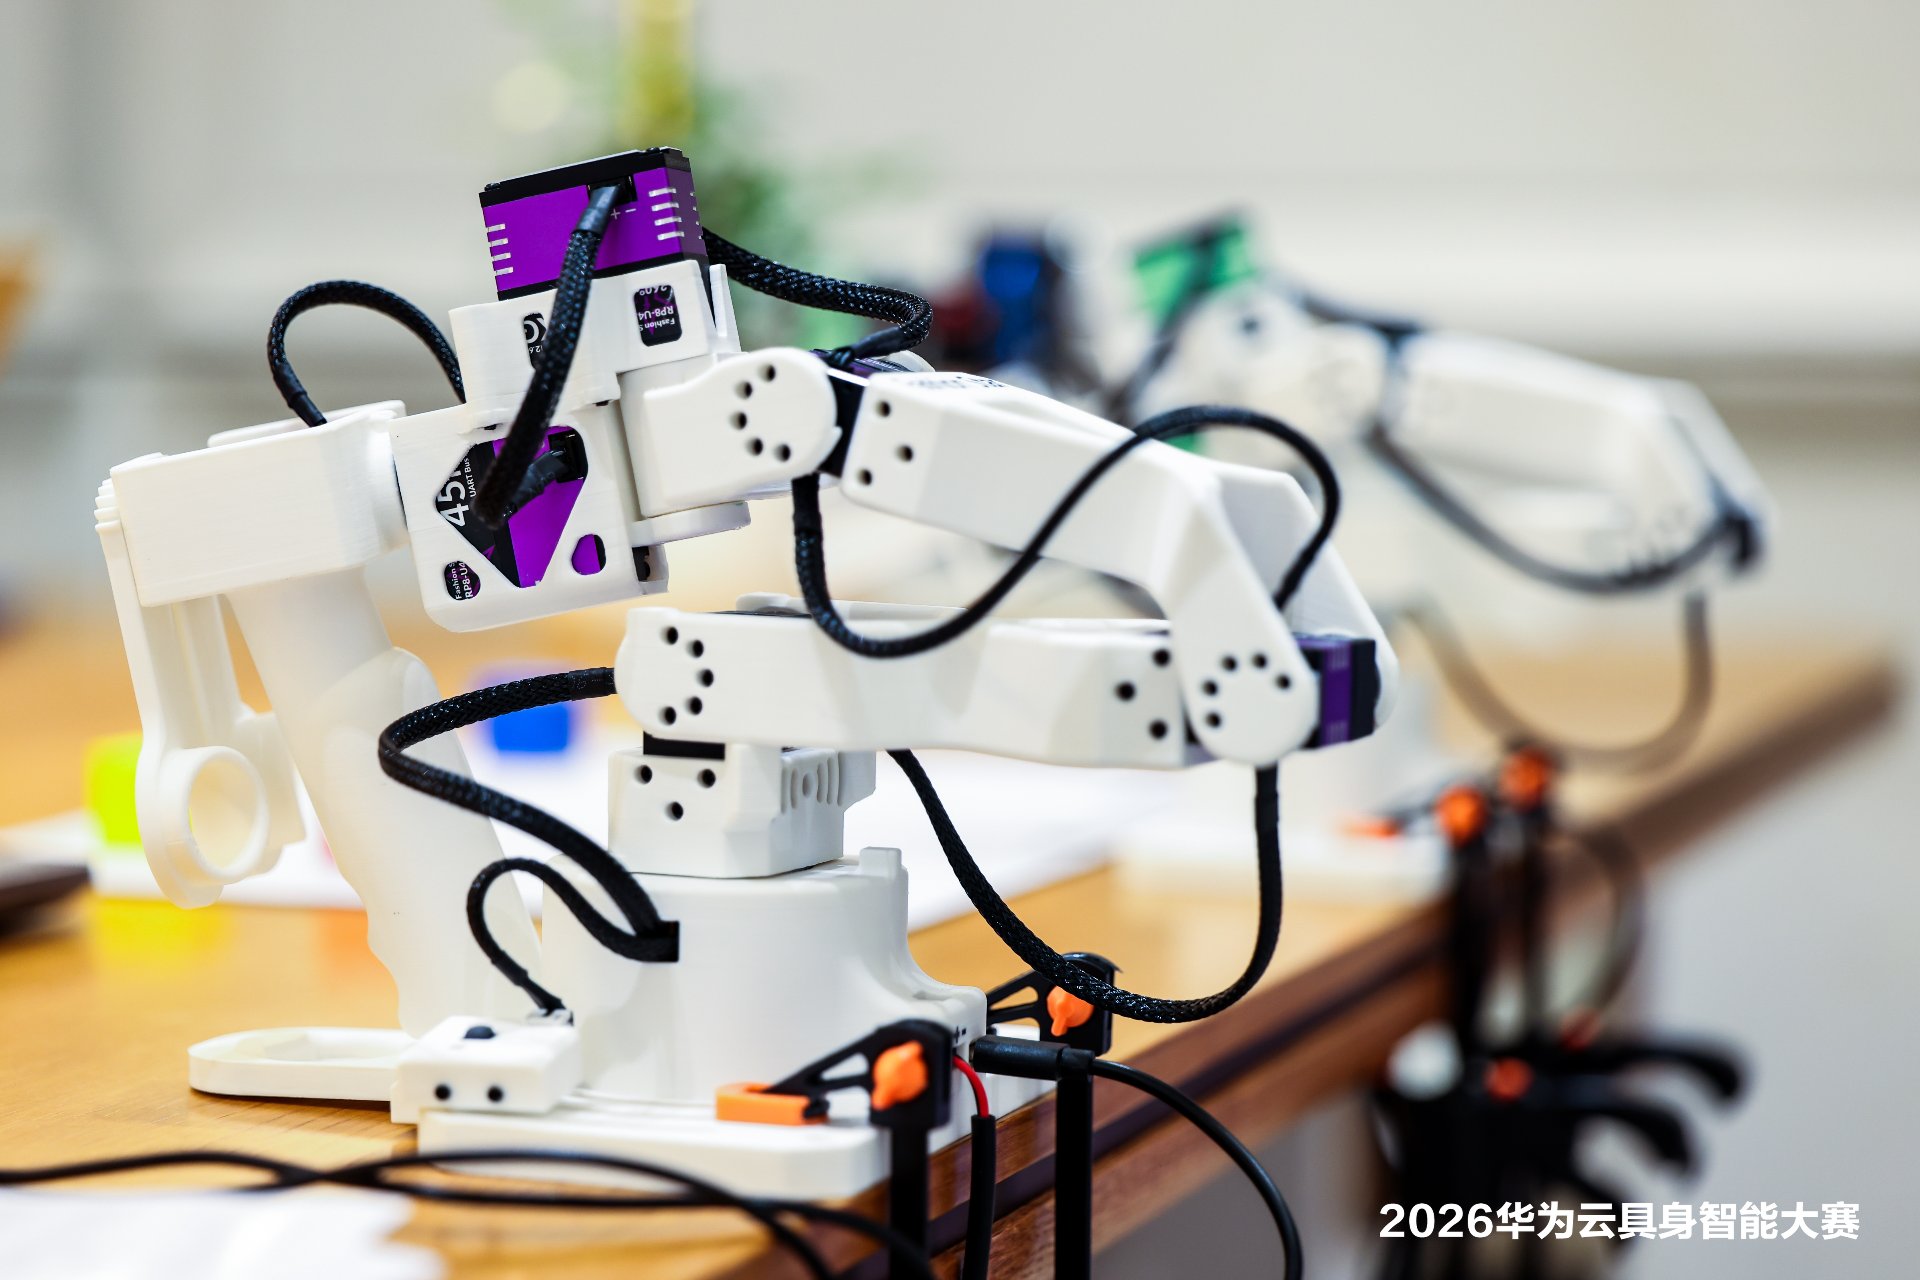
Star Arm 102-LD
Lightweight leader arm — 663 g, built with RA8 series low-damping servos for handheld teaching and rapid data collection.
Star Arm 102-HD
Hover leader arm — holds its pose when released, with a 420 mm reach and RP8-U45H-M high-torque servos for professional, high-precision demonstration capture.
Star Arm 102-FL
Follower arm — 5–8 mm repeatability and a 300 g suggested payload, supporting task execution, automation experiments and physical operation.
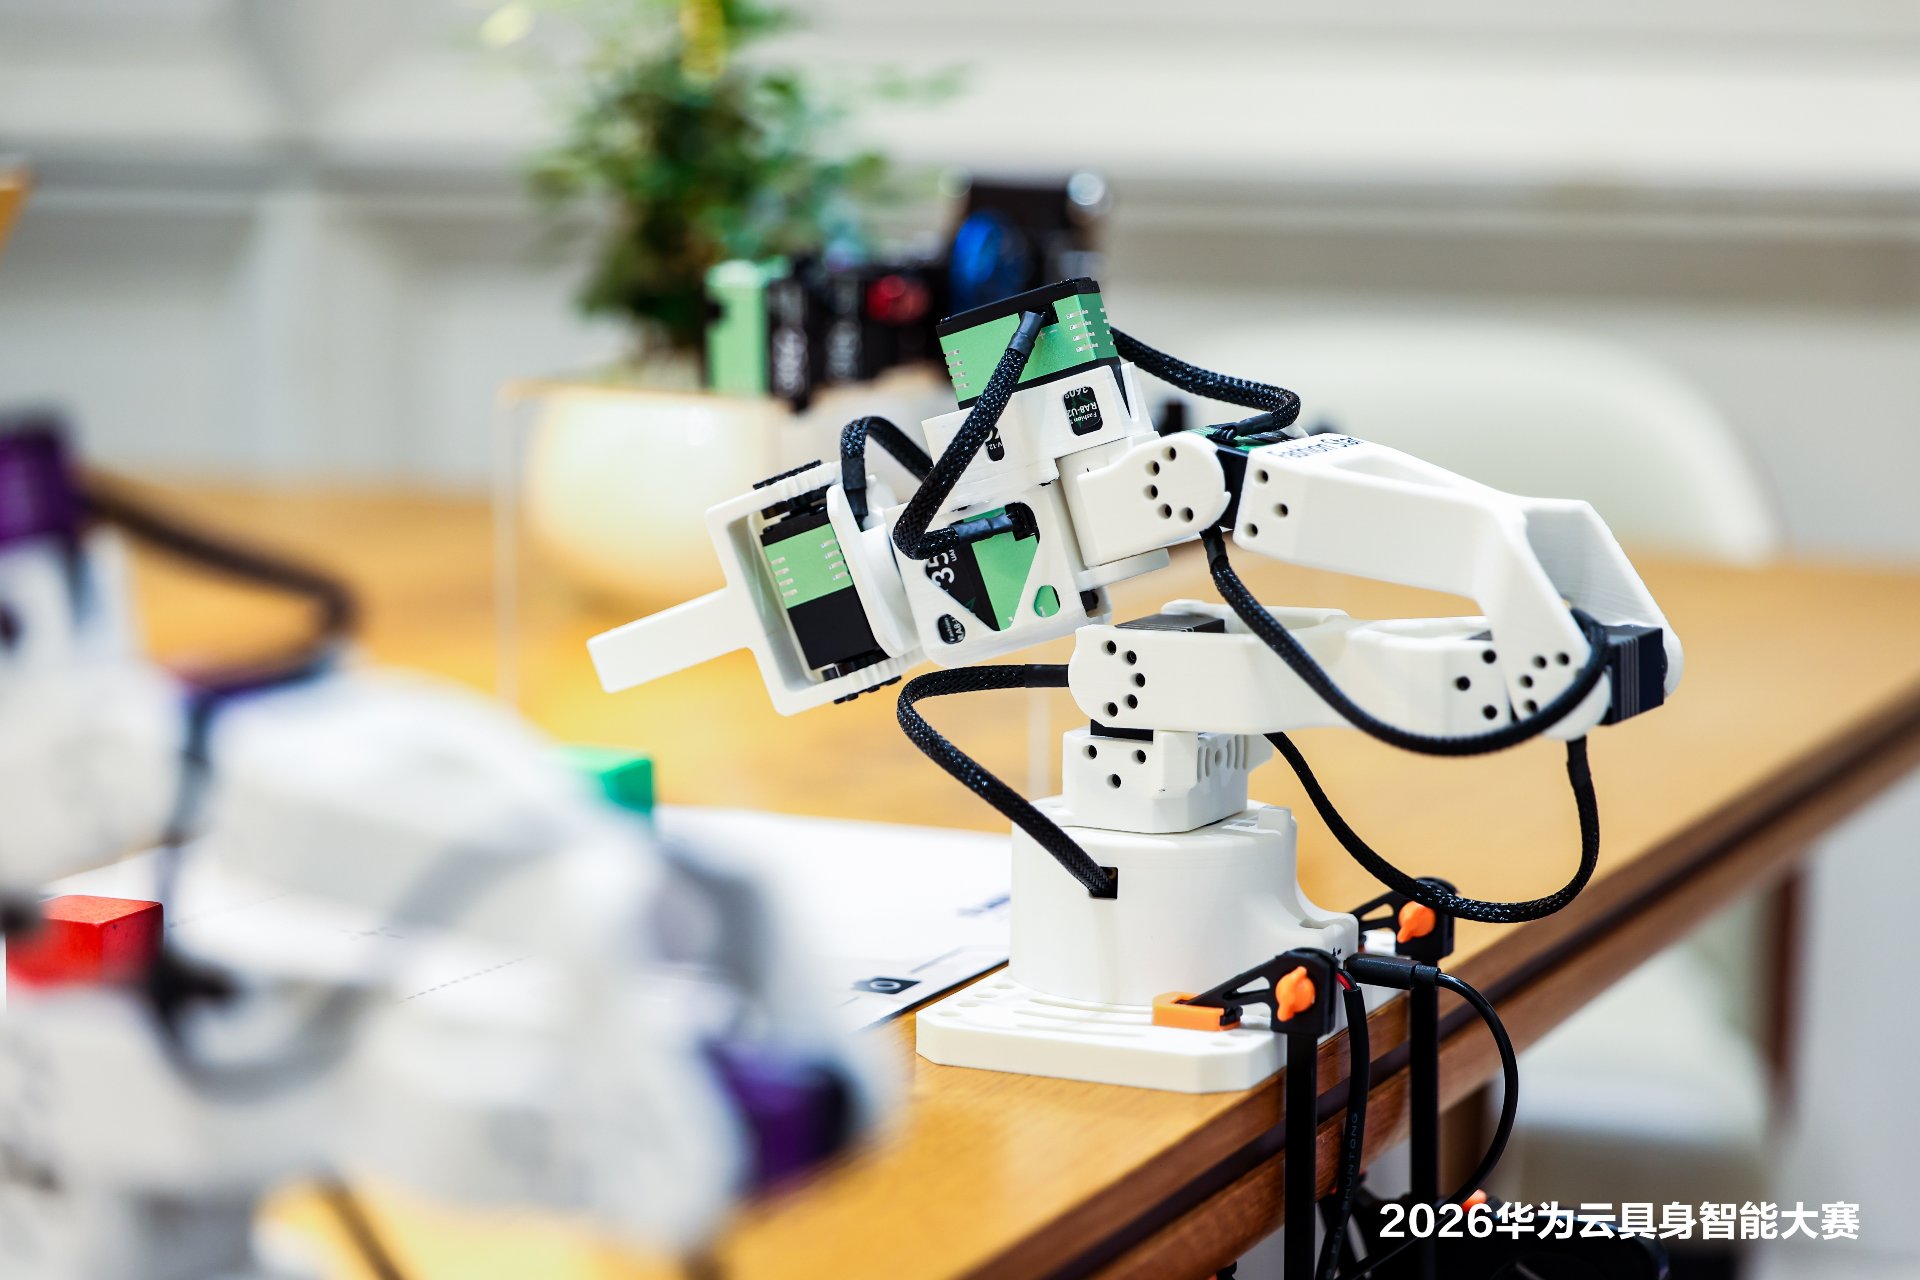
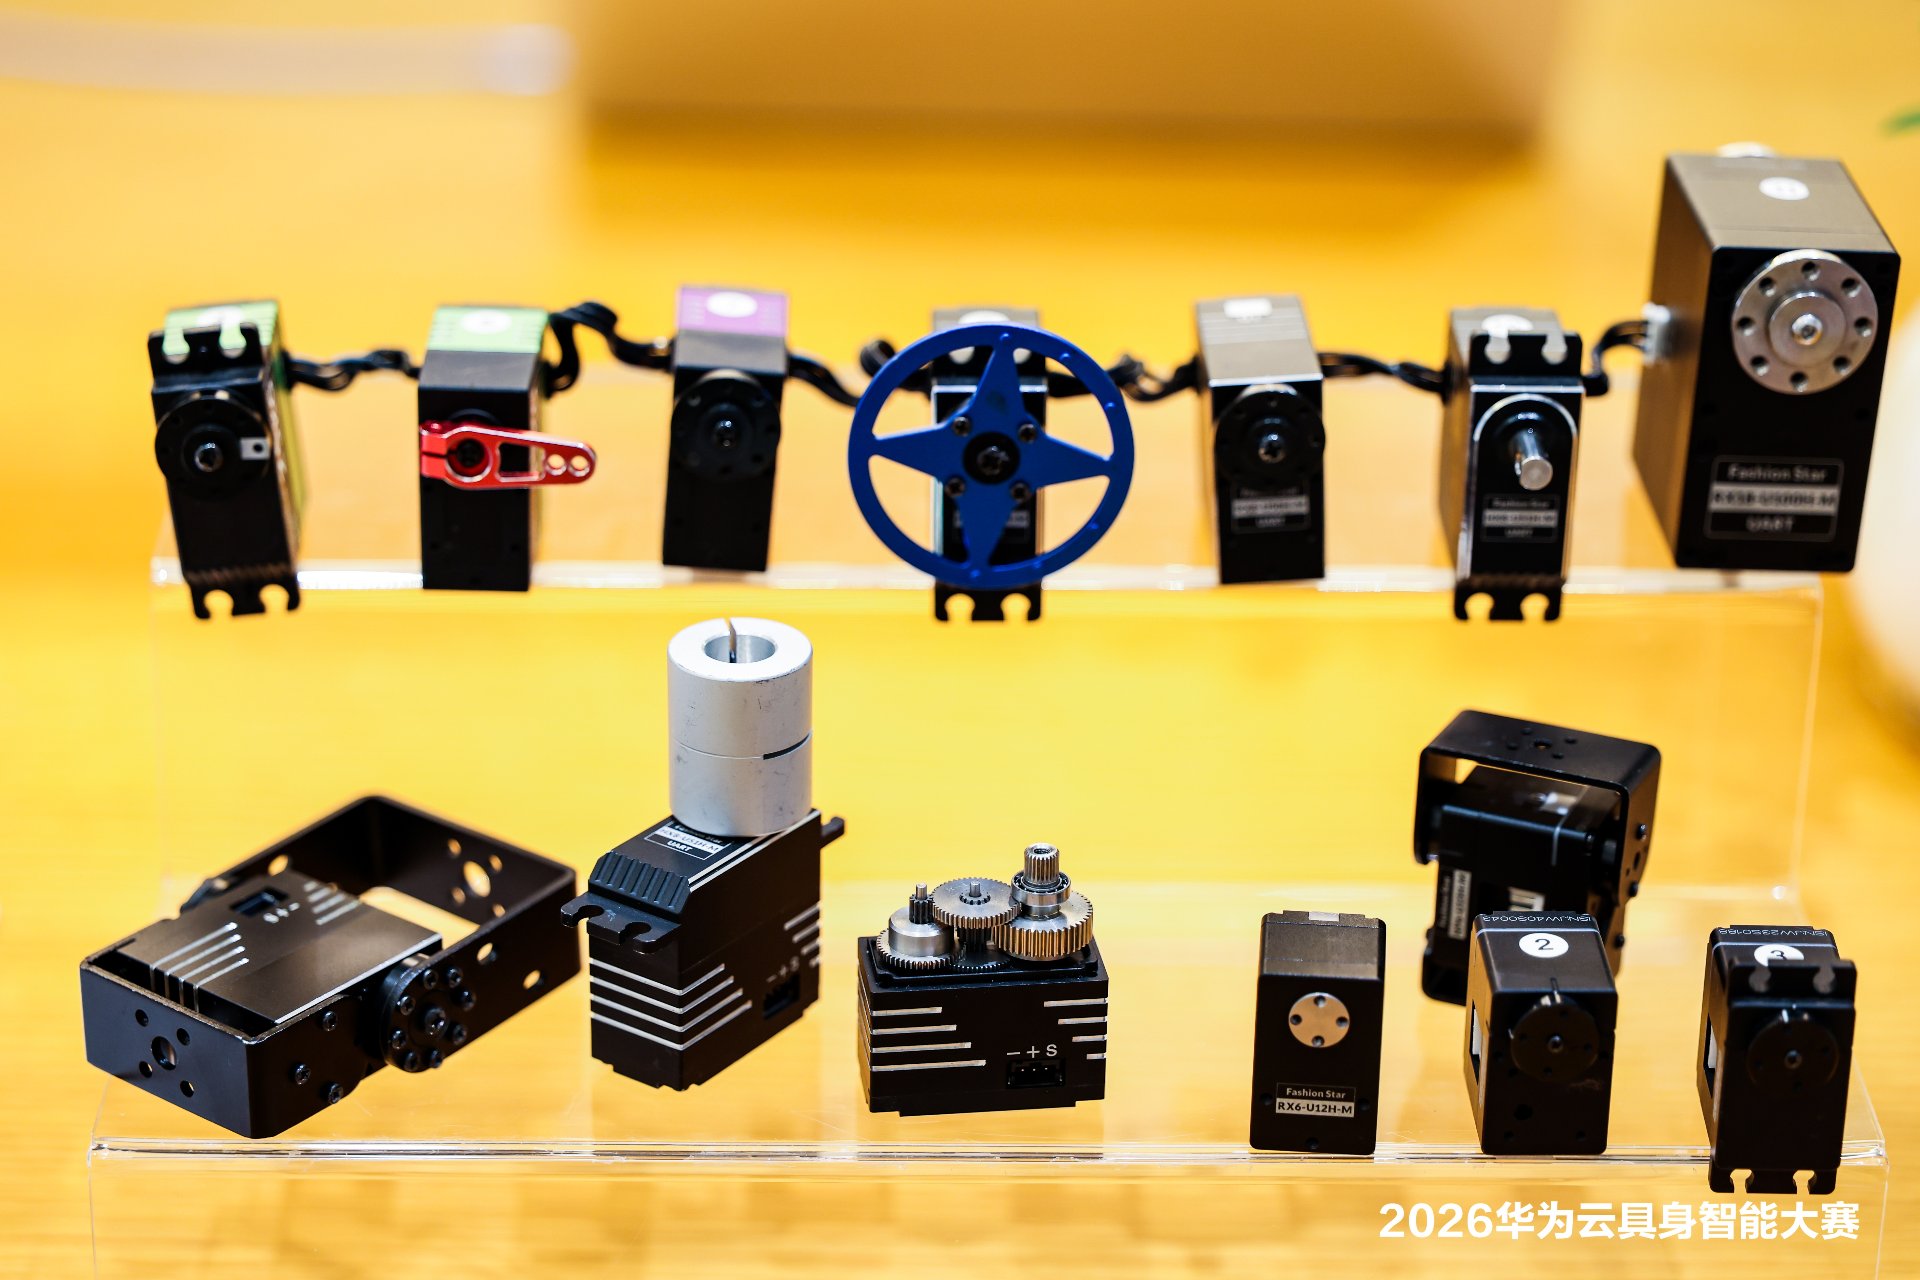
Shared across the series: 12-bit magnetic encoders for joint-angle feedback, UART communication through a UC-01 hub, and support for Python SDK, ROS2 Humble and Hugging Face LeRobot. The LD and HD models run as LeRobot teleoperators, while the FL serves as the execution robot; the FL also supports MoveIt2 motion planning and Gazebo simulation.
Star Arm 102 is documented in the Hugging Face LeRobot documentation as a supported teleoperator, and the full hardware and software stack — control code, CAD drawings and printable structural parts — is published in the open-source servodevelop/Star-Arm-102 repository.
Building with Real Hardware Under Time Constraints
A three-day event like the Huawei Cloud Embodied AI Competition is a practical test of a robotics platform. When participants have limited setup and development time, hardware has to be understandable, responsive and fast to integrate.
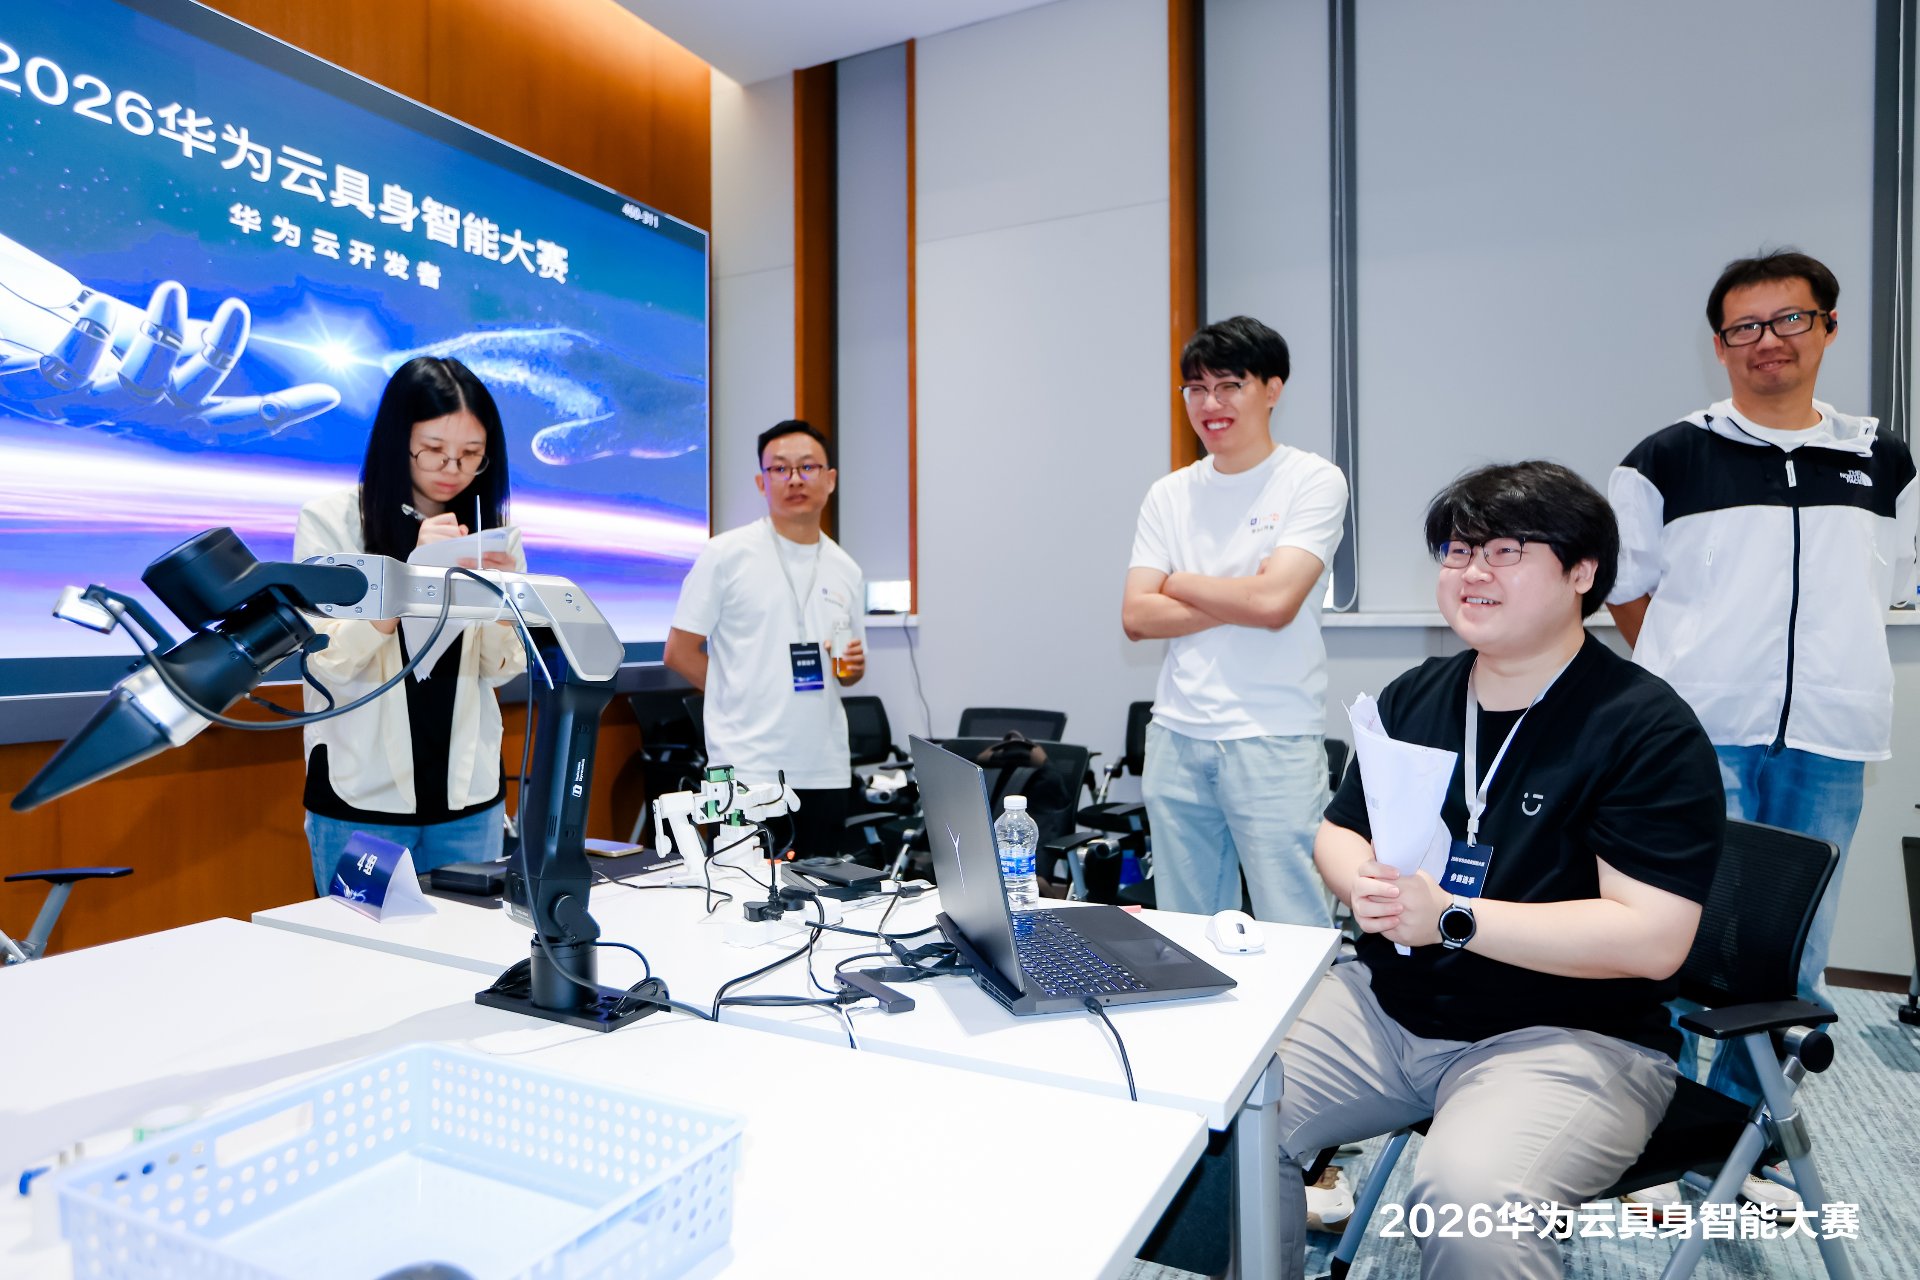
Across three days of finals, teleoperation stations were moved, re-powered and re-zeroed repeatedly between teams. Star Arm 102’s browser-based controller proved useful in that setting: no environment to install and no code to write — real-time control, joint-angle monitoring, one-click zero calibration and PID tuning from a browser tab. When an arm drifted out of alignment, teams could recalibrate on the spot instead of losing competition time.
The leader–follower configuration also showed how a direct teleoperation interface helps developers evaluate physical tasks and begin collecting demonstration data within a compressed development cycle.
Supporting the Embodied AI Developer Community
FashionStar develops bus servos, robotic arms and robotic systems for research, education and embodied AI applications. The Star Arm 102 Series supports teleoperation, robot data collection and imitation-learning workflows across leader, follower, single-arm and dual-arm configurations.
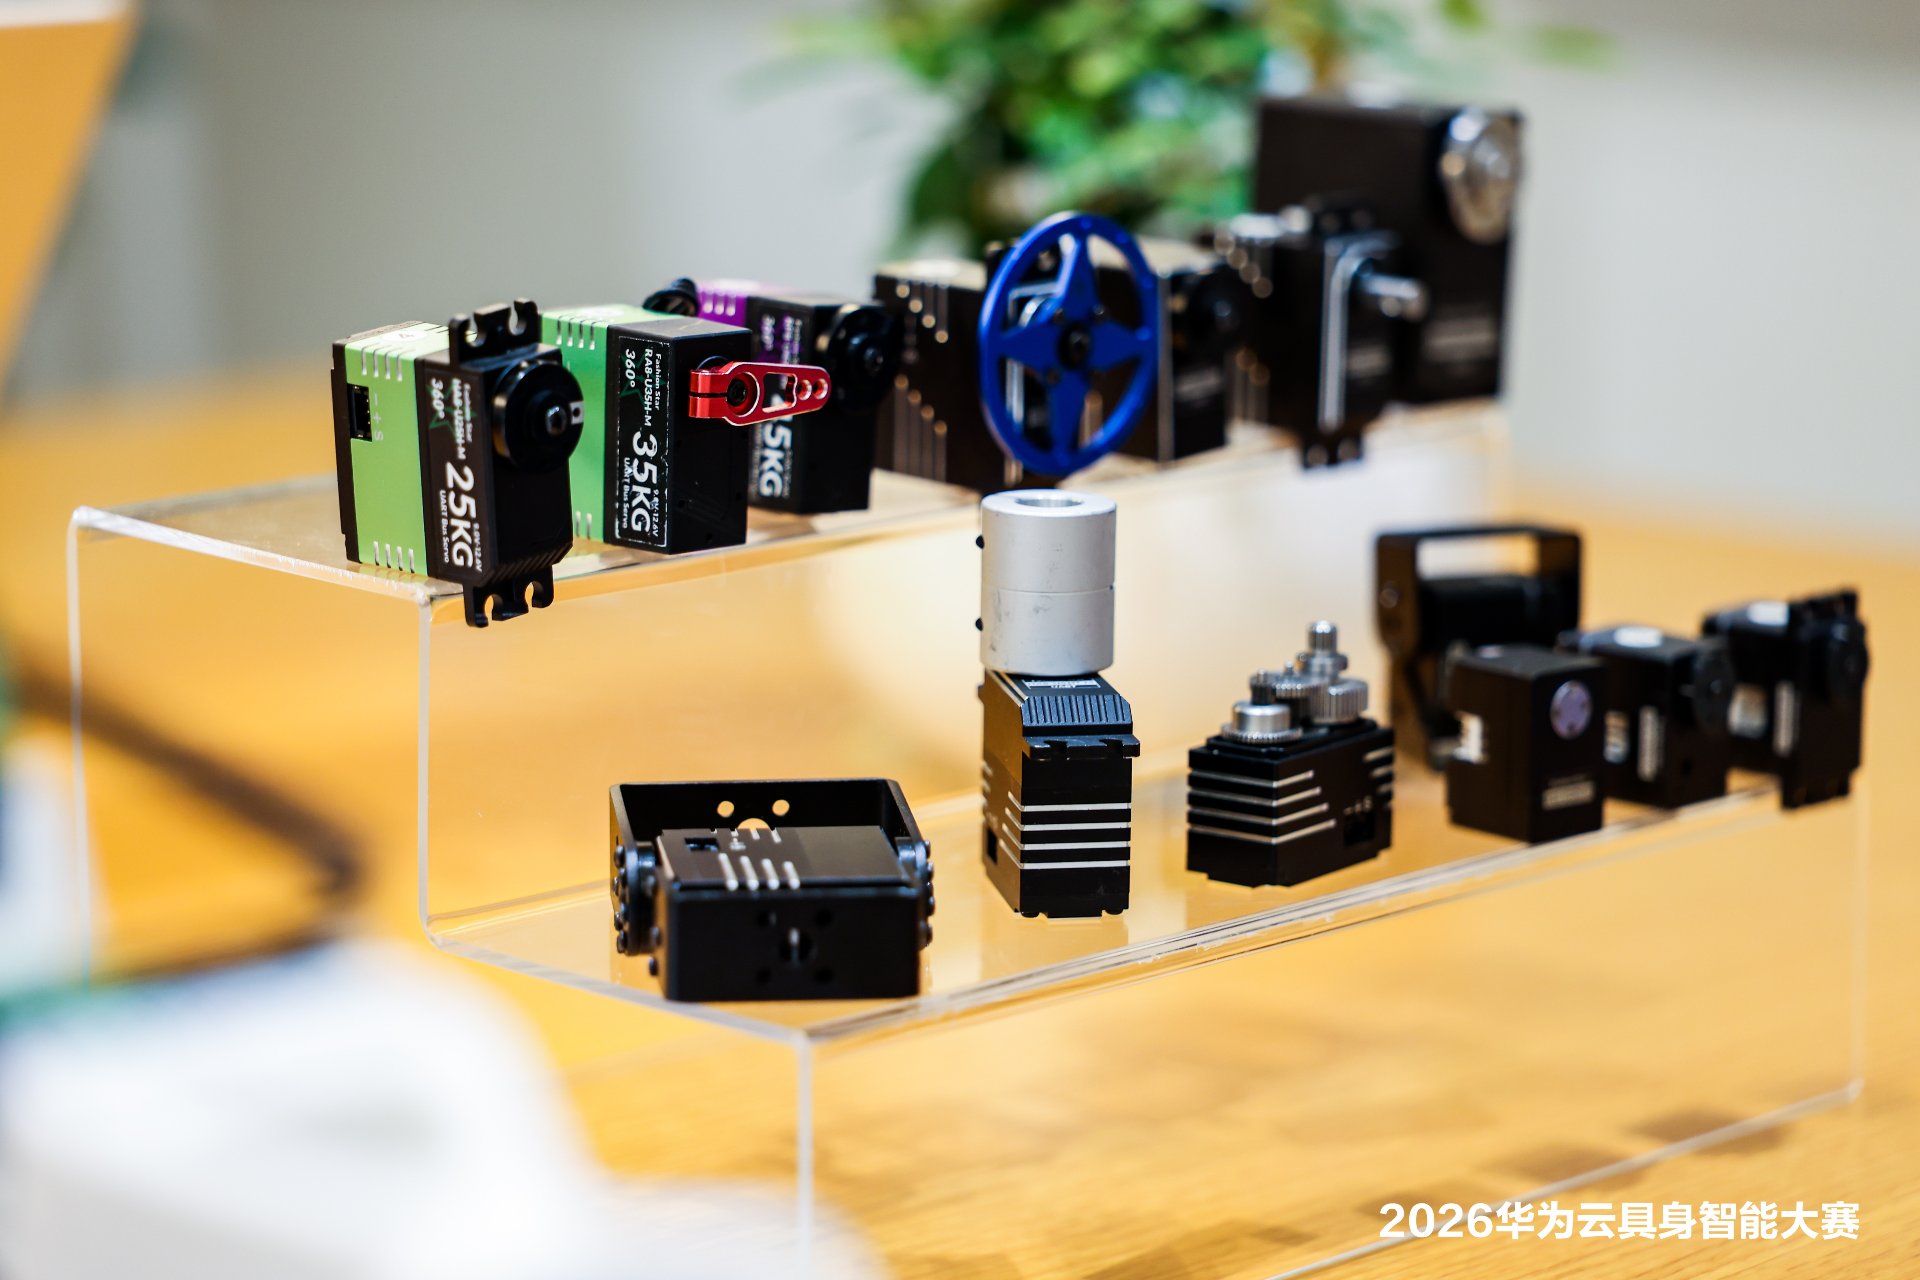
Its role at the Huawei Cloud Embodied AI Competition reflects a broader objective: helping developers work with real robot behavior, collect useful demonstrations, and progress efficiently from manual operation toward learned robot policies.
Technical Resources
- Platform overview: Star Arm 102 open-source teleoperation platform
- Ecosystem integration: Star Arm 102 with Hugging Face LeRobot
- Technical documentation: Star Arm 102 Wiki
- External reference: Hugging Face LeRobot robot-arm documentation
- Open-source repository: GitHub — servodevelop/Star-Arm-102
- Company website: FashionStar robotics and motion-control solutions
Build Your Embodied AI Data Collection Workflow with Star Arm 102
Explore the leader–follower teleoperation, synchronized robot data collection and imitation-learning workflow that Star Arm 102 supported at the Huawei Cloud Embodied AI Competition.